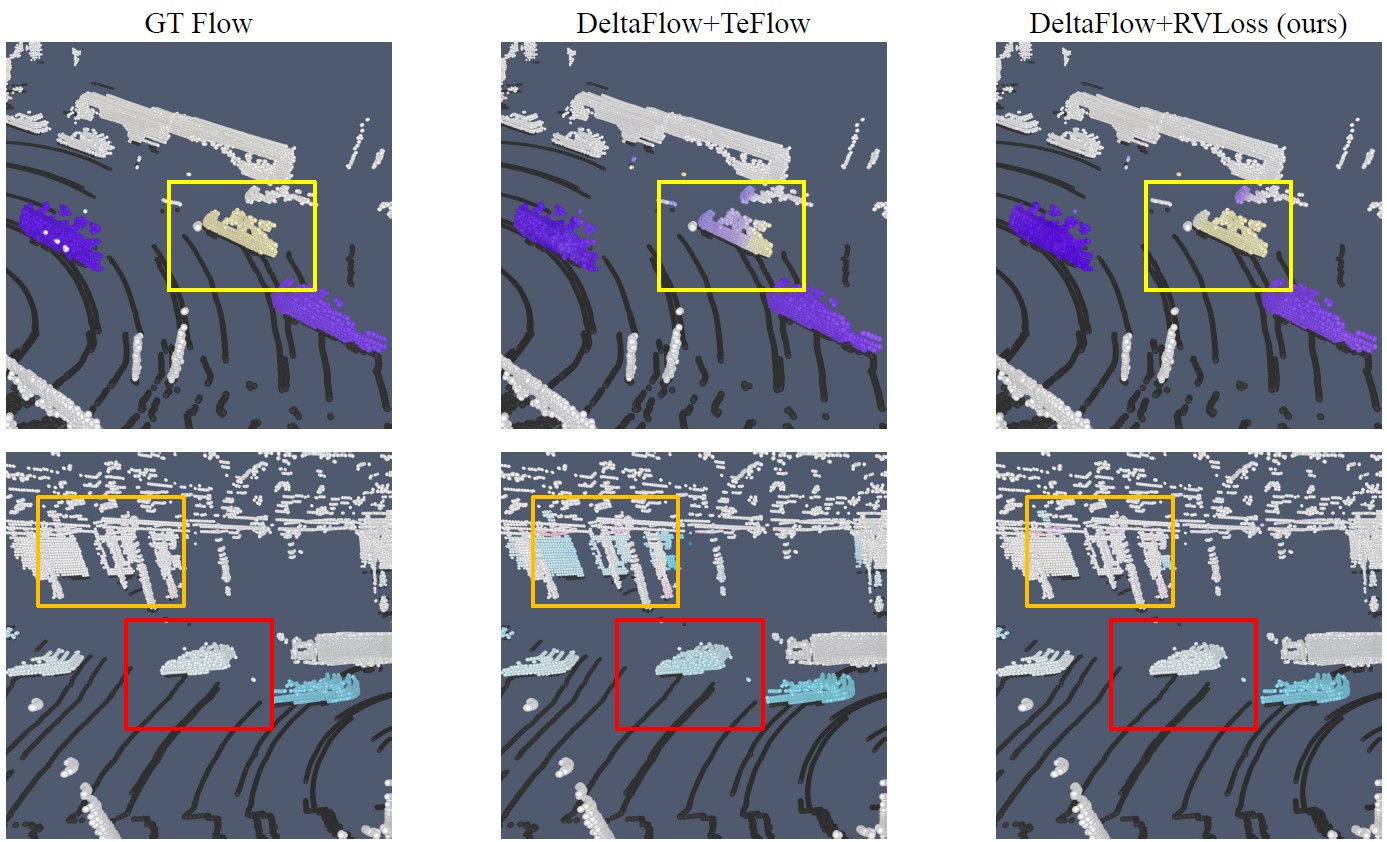
RVLoss: Runoff Vote Loss for Self-Supervised LiDAR Scene Flow Estimation
S. Wang, L. Nan, J.F.P. Kooij, H. Caesar, Y. Lin, Neural Information Processing Systems (NeurIPS), 2026. to appear
Cite this work
@inproceedings{rvloss,
    title={{RVLoss: Runoff Vote Loss for Self-Supervised LiDAR Scene Flow Estimation}},
    author={S. Wang and L. Nan and J.F.P. Kooij and H. Caesar and Y. Lin},
    booktitle={Neural Information Processing Systems (NeurIPS)},
    pages={},
    year={2026},
    doi={},
}